Project Overview
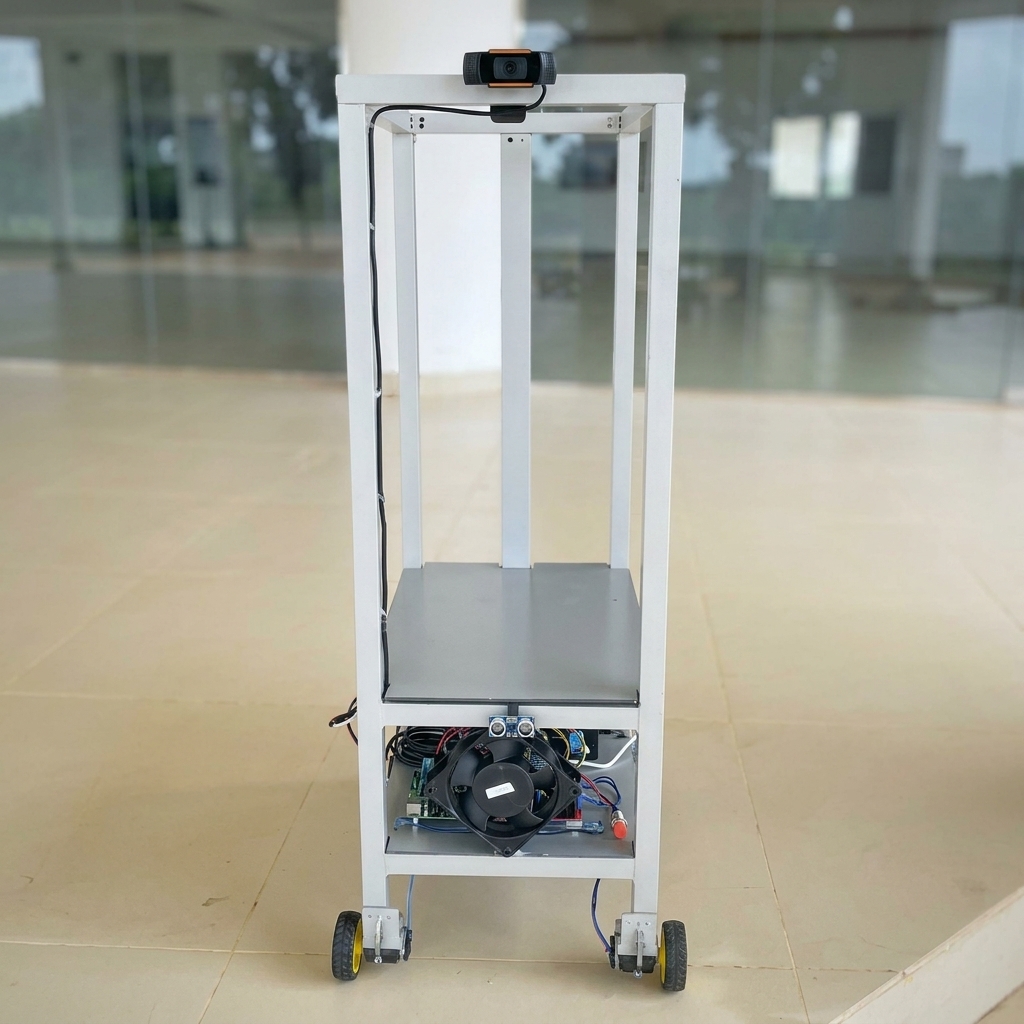
Marker-Based Human-Following Robot Using YOLOv8 for Assistive Load Transportation Developed an autonomous human-following mobile robot that tracks a user wearing a red circular marker to assist with indoor load carrying in healthcare, logistics, and public environments. The system is built on a Raspberry Pi 5 with a 720p RGB camera, differential-drive base, and dual IR sensors, enabling real-time detection and safe navigation on low-cost hardware.
Problem
Marker-Based Human-Following Robot Using YOLOv8 for Assistive Load Transportation Developed an autonomous human-following mobile robot that tracks a user wearing a red circular marker to assist with indoor load carrying in healthcare, logistics, and public environments. .
Solution
Marker-Based Human-Following Robot Using YOLOv8 for Assistive Load Transportation Developed an autonomous human-following mobile robot that tracks a user wearing a red circular marker to assist with indoor load carrying in healthcare, logistics, and public environments. The system is built on a Raspberry Pi 5 with a 720p RGB camera, differential-drive base, and dual IR sensors, enabling real-time detection and safe navigation on low-cost hardware.
Features
Implemented vision-based steering and distance control using bounding-box geometry, removing the need for external range sensors and achieving accurate, robust following performance in crowded indoor trials.
Technologies Used
Python, YOLO, OpenCV, Raspberry Pi
Results
Implemented vision-based steering and distance control using bounding-box geometry, removing the need for external range sensors and achieving accurate, robust following performance in crowded indoor trials.
Project Summary
Category: AI / Computer Vision / Image Processing project
Technologies: Python, YOLO, OpenCV, Raspberry Pi
Results: Implemented vision-based steering and distance control using bounding-box geometry, removing the need for external range sensors and achieving accurate, robust following performance in crowded indoor trials.